Build a legged robot
The bill of materials for a quadruped or humanoid: high-torque joints for the hips and knees, motors and reducers if you build the legs yourself, encoders, drivers, servos for hands and small joints, and onboard compute for perception and control.
Leg joints
Hips and knees carry the body and take the impacts of every step. Many legged robots use backdrivable, low-ratio joints for this.
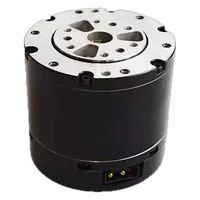 RobStride RS00 QDD Joint ActuatorRobStride · CN · $84.23
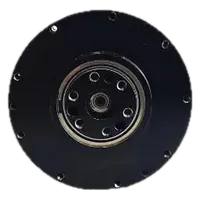 RobStride RS02 QDD Joint ActuatorRobStride · CN · $98.45
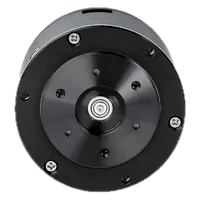 CubeMars AK40-10 V3.0 KV170 Robotic ActuatorCubeMars · CN · $135.90
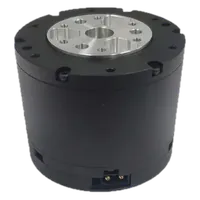 Damiao DM-J4310-2EC Joint MotorDamiao · CN · $139.99
81 parts in all. Open a list above to filter by size, torque and where it is made.
Or build the leg joints
An outrunner or frameless motor with a planetary reducer is the usual quasi-direct-drive leg joint. Every part one joint needs.
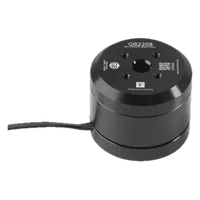 T-Motor GB2208 KV128 Gimbal MotorT-Motor · CN · $25.90
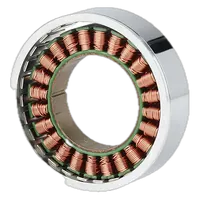 CubeMars RO40 KV140 Lite Frameless Outrunner Torque MotorCubeMars · CN · $51.90
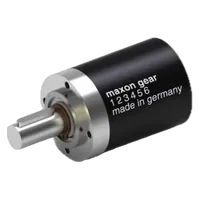 maxon GP 42 C Planetary Gearhead, 3.5:1maxon · CH · $306.71
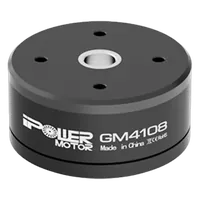 iFlight iPower GM4108H-120T Gimbal MotoriFlight · CN · $35.90
109 parts in all. Open a list above to filter by size, torque and where it is made.
 ams OSRAM AS5600 12-bit Magnetic Angle Sensor ICams OSRAM · AT · $1.73
 MagnTek MT6701 14-bit Hall Magnetic Angle Sensor ICMagnTek (NOVOSENSE) · CN · $1.43
 Semiment SC60228 12-bit Hall Angle Sensor IC (SPI)Semiment · CN · $1.66
 Conntek KTH7823 16-bit Hall Magnetic Encoder IC (SSI/PWM)Conntek · CN · $2.03
90 parts in all. Open a list above to filter by size, torque and where it is made.
Drivers
Fast current control on every leg joint, usually over CAN or EtherCAT.
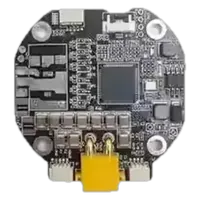 SteadyWin GDS68 Joint Motor Driver Board (SDC104)SteadyWin · CN · $33.99
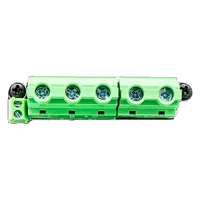 Makerbase MKS XDrive Mini FOC Servo Controller (ODrive 3.6-based)Makerbase · CN · $40.99
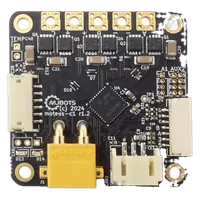 mjbots moteus-c1 Brushless Servo Controllermjbots · US · $69
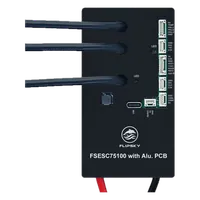 Flipsky 75100 VESC-Based ESC (Aluminum PCB)Flipsky · CN · $73
43 parts in all. Open a list above to filter by size, torque and where it is made.
Hands and small joints
Smart servos for fingers, grippers, heads and other light joints.
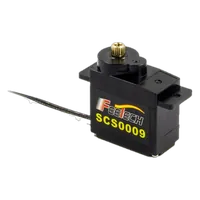 Feetech SCS0009 Micro Serial Bus ServoFeetech · CN · $8.99
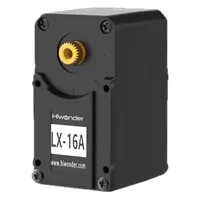 Hiwonder LX-16A Serial Bus ServoHiwonder · CN · $16.99
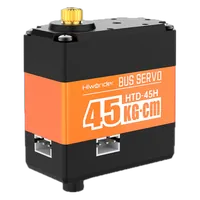 Hiwonder HTD-45H High-Voltage Serial Bus ServoHiwonder · CN · $24.99
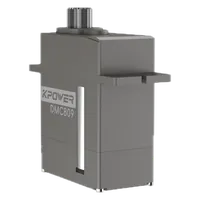 Kpower DMC809 Coreless Metal-Gear Digital ServoKpower · CN · $26.69
12 parts in all. Open a list above to filter by size, torque and where it is made.
Onboard compute
Perception, state estimation and the control policy.
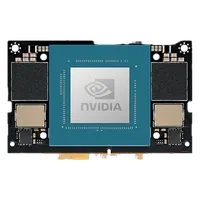 Jetson Orin Nano 4GB ModuleNVIDIA · US · $399
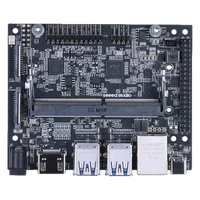 reComputer J401 Carrier BoardSeeed Studio · CN · $163.50
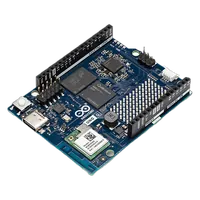 Arduino UNO Q (2GB/16GB ABX00162, 4GB/32GB ABX00173)Arduino · IT · $44
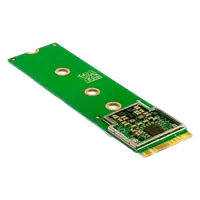 Coral M.2 Accelerator (Edge TPU), B+M keyCoral (Google) · US · $44.99
30 parts in all. Open a list above to filter by size, torque and where it is made.
Test the joints
Measure torque, backlash and heat on the bench before the robot falls on them. The test protocol and bench kits.
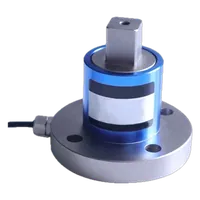 ATO Flange-to-Square-Drive Reaction Torque Sensor, 50 N·m (ATO-TQS-S03)ATO · CN · $134.92
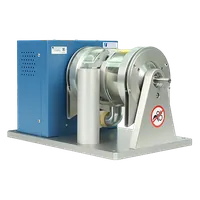 Magtrol HD-715-5C Hysteresis Dynamometer (6.2 N·m)Magtrol · US · Quote
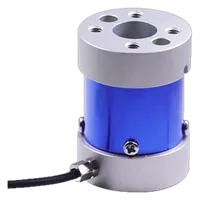 ATO Micro Reaction Torque Sensor, 10 N·m (ATO-TQS-S04 / ATO-DYJN-104)ATO · CN · $175.93
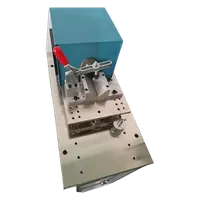 Changniu CNC100K S/E Hysteresis Dynamometer (10 N·m)Changniu · CN · Quote
26 parts in all. Open a list above to filter by size, torque and where it is made.
Not sure which combination fits? Send what you are building and the numbers you need, and Maglev comes back with a matched set and one fixed price.
How ordering works