Build a robot arm
The bill of materials for a robot arm: a joint actuator for each axis, bought integrated or built from a motor, reducer and encoder, brakes on the joints that carry the arm, smart servos for the wrist and gripper, drivers and a controller.
Joints
One per axis. Integrated joints are the fastest path; size the shoulder and elbow for the arm's reach and payload.
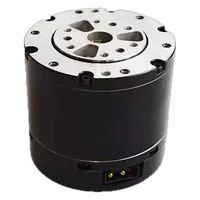 RobStride RS00 QDD Joint ActuatorRobStride · CN · $84.23
 RobStride RS02 QDD Joint ActuatorRobStride · CN · $98.45
 CubeMars AK40-10 V3.0 KV170 Robotic ActuatorCubeMars · CN · $135.90
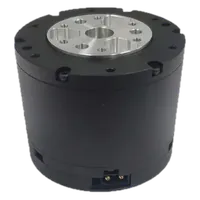 Damiao DM-J4310-2EC Joint MotorDamiao · CN · $139.99
81 parts in all. Open a list above to filter by size, torque and where it is made.
Or build the joints
A frameless motor with a strain-wave or cycloidal reducer gives a compact, stiff joint. Every part one joint needs.
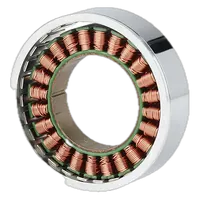 CubeMars RO40 KV140 Lite Frameless Outrunner Torque MotorCubeMars · CN · $51.90
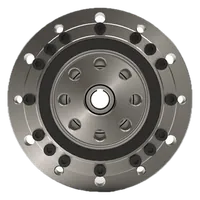 Harmonic Drive CSF-14-100-2UH Strain-Wave Gear UnitHarmonic Drive · JP · Quote
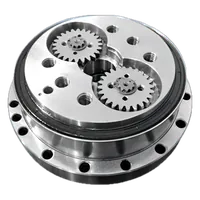 Qinchuan BX20E RV ReducerQinchuan · CN · $460
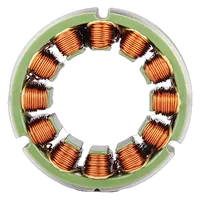 CubeMars RI50 KV100 Frameless Inrunner Torque MotorCubeMars · CN · $61.90
161 parts in all. Open a list above to filter by size, torque and where it is made.
Holding brakes
The shoulder and elbow carry the arm's weight. A brake keeps the arm from dropping when power is cut.
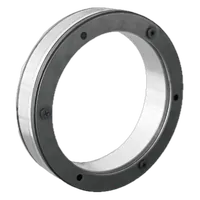 REACH REB16-06 Large-Bore Permanent Magnet Brake (2.5 Nm)REACH · CN · Quote
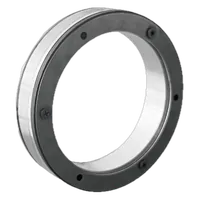 REACH REB16-08 Large-Bore Permanent Magnet Brake (8 Nm)REACH · CN · Quote
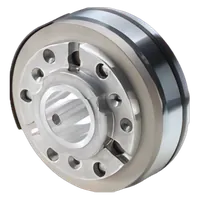 STEKI SMB04-11 Permanent Magnet Brake (2.5 Nm)STEKI · CN · Quote
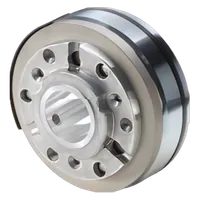 STEKI SMB06-11 Permanent Magnet Brake (9 Nm)STEKI · CN · Quote
27 parts in all. Open a list above to filter by size, torque and where it is made.
Encoders
An absolute encoder on each joint output means the arm knows where it is at power-up.
 ams OSRAM AS5600 12-bit Magnetic Angle Sensor ICams OSRAM · AT · $1.73
 Same Sky (CUI) AMT102-V Capacitive Incremental EncoderSame Sky (formerly CUI Devices) · US · $36.29
 MagnTek MT6701 14-bit Hall Magnetic Angle Sensor ICMagnTek (NOVOSENSE) · CN · $1.43
 Renishaw RESOLUTE Rotary Readhead, BiSS 32-bit, 150 mm RingRenishaw · UK · Quote
98 parts in all. Open a list above to filter by size, torque and where it is made.
Wrist and gripper
Smart serial servos and small linear actuators for the light joints at the end of the arm.
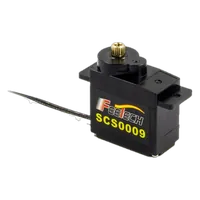 Feetech SCS0009 Micro Serial Bus ServoFeetech · CN · $8.99
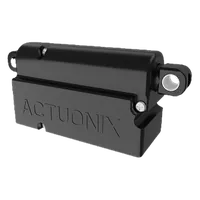 Actuonix PQ12-P Micro Linear Actuator, 20 mm, 63:1, 12 VActuonix · CA · $65
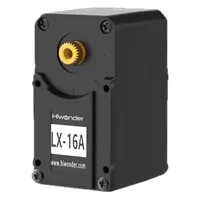 Hiwonder LX-16A Serial Bus ServoHiwonder · CN · $16.99
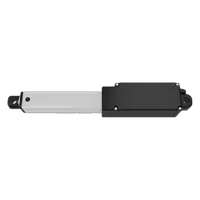 Actuonix L16-P Miniature Linear Actuator, 50 mm, 63:1, 12 VActuonix · CA · $80
17 parts in all. Open a list above to filter by size, torque and where it is made.
Drivers
FOC servo drivers for joints that do not have one built in, on CAN or EtherCAT.
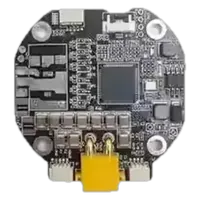 SteadyWin GDS68 Joint Motor Driver Board (SDC104)SteadyWin · CN · $33.99
 Makerbase MKS XDrive Mini FOC Servo Controller (ODrive 3.6-based)Makerbase · CN · $40.99
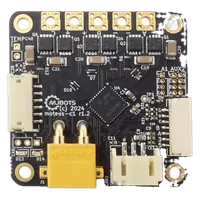 mjbots moteus-c1 Brushless Servo Controllermjbots · US · $69
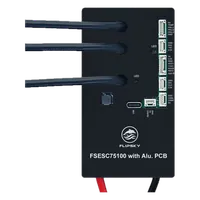 Flipsky 75100 VESC-Based ESC (Aluminum PCB)Flipsky · CN · $73
43 parts in all. Open a list above to filter by size, torque and where it is made.
Controller
Runs motion planning and, with a camera, perception.
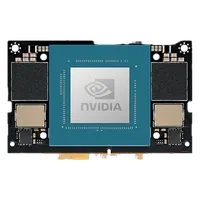 Jetson Orin Nano 4GB ModuleNVIDIA · US · $399
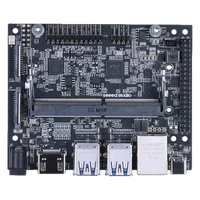 reComputer J401 Carrier BoardSeeed Studio · CN · $163.50
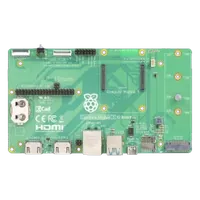 Raspberry Pi Compute Module 5 IO Board (Rev 2)Raspberry Pi · GB · $26.95
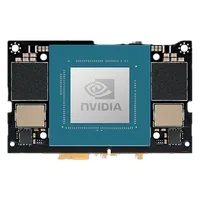 Jetson Orin Nano 8GB ModuleNVIDIA · US · $449
23 parts in all. Open a list above to filter by size, torque and where it is made.
Links and brackets
The arm's structure is usually custom. Maglev Make lists shops that machine it from your CAD. CNC milling shops.
Not sure which combination fits? Send what you are building and the numbers you need, and Maglev comes back with a matched set and one fixed price.
How ordering works